{
"markdown": "\n\n

\n\n# Jaxonomy\n\n**Differentiable simulation of hybrid dynamical systems — powered by JAX.**\n\n[](https://pypi.org/project/jaxonomy/)\n[](https://www.python.org/)\n[](https://github.com/machinavitalis/jaxonomy/blob/main/LICENSE.md)\n[](https://py.jaxonomy.com)\n\n*Block diagrams meet automatic differentiation. Model physical systems, close the loop with LQR/MPC/Kalman, and differentiate through everything.*\n\n**[Why JAX?](#-why-jax)** · **[Install](#-installation)** · **[Quick Start](#-quick-start)** · **[Gallery](#-gallery)** · **[Examples](#-examples)** · **[Docs](https://py.jaxonomy.com)**\n\n
Every panel above is produced by jaxonomy.simulate on a model built from the library.\n\n
\n\n

\n\n
\n\n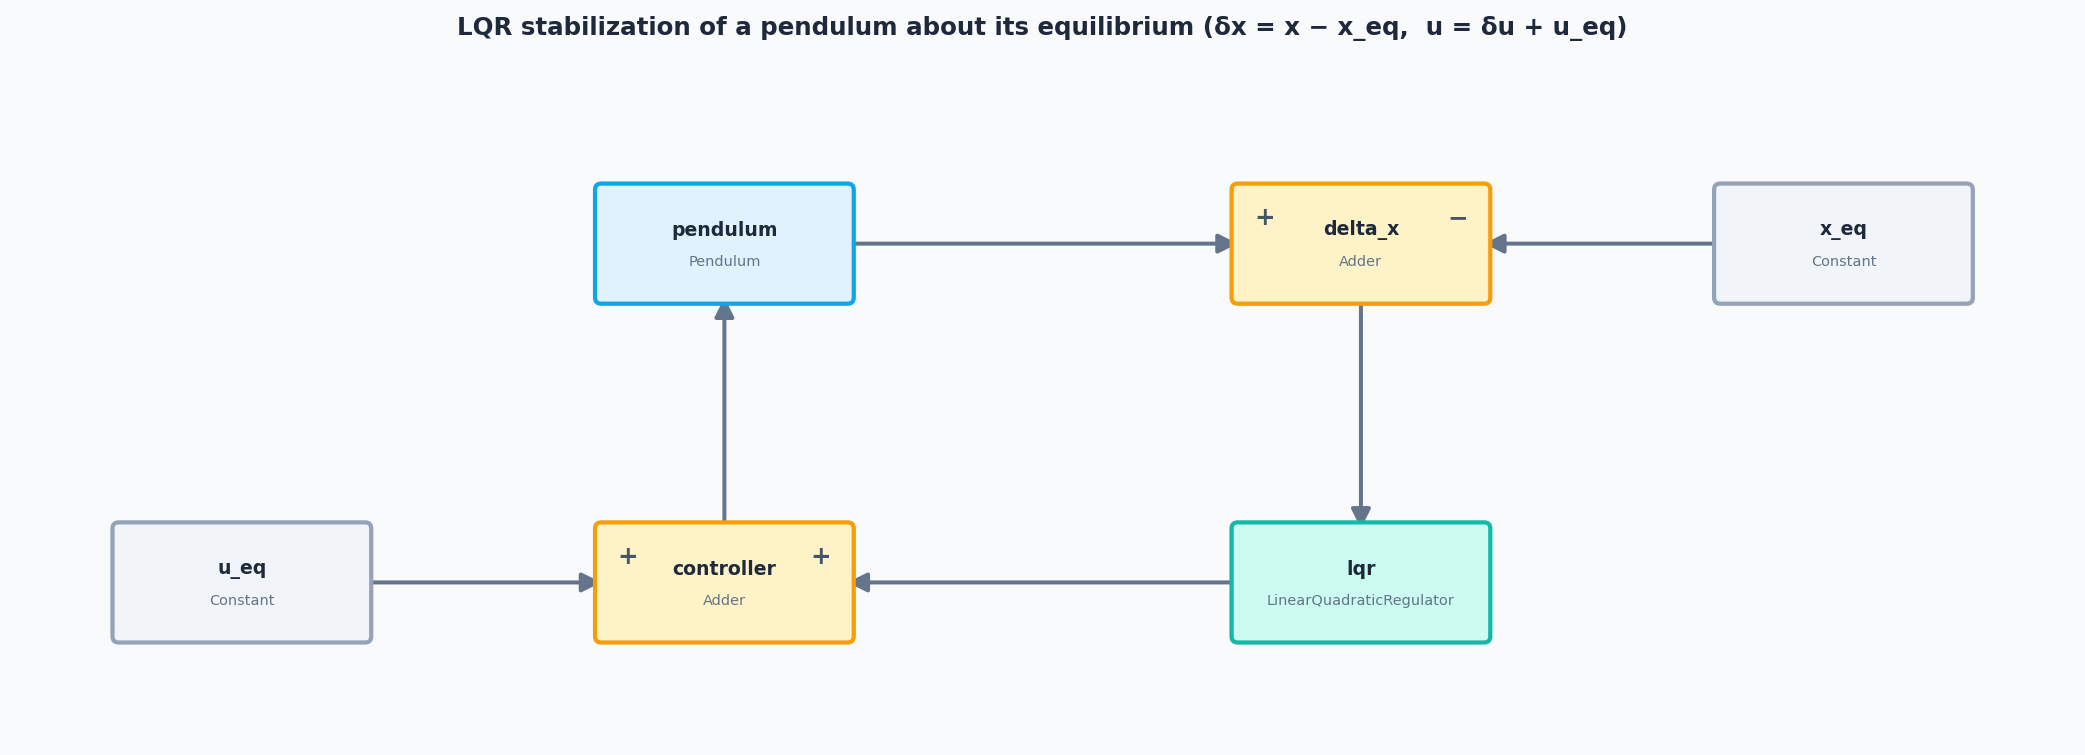\n\n
\n\nFor a linearized pendulum with state $x = [\\theta, \\dot\\theta]^\\top$:\n\n$$\n\\dot{x} = Ax + Bu, \\qquad\nA = \\begin{bmatrix} 0 & 1 \\\\ g/L & 0 \\end{bmatrix}, \\quad\nB = \\begin{bmatrix} 0 \\\\ 1/mL^2 \\end{bmatrix}\n$$\n\nThe **Linear Quadratic Regulator** minimizes infinite-horizon cost:\n\n$$\nJ = \\int_0^\\infty \\bigl( x^\\top Q\\, x + u^\\top R\\, u \\bigr)\\, dt\n$$\n\nby solving the algebraic Riccati equation $A^\\top P + PA - PBR^{-1}B^\\top P + Q = 0$ for the optimal gain $K = R^{-1}B^\\top P$, so $u^* = -Kx$.\n\n```python\nimport jaxonomy as jx\nfrom jaxonomy.library import LTISystem, LinearQuadraticRegulator\nimport jax.numpy as jnp\n\ng, L, m = 9.81, 1.0, 1.0\nA = jnp.array([[0, 1], [g/L, 0]])\nB = jnp.array([[0], [1 / (m * L**2)]])\nC, D = jnp.eye(2), jnp.zeros((2, 1))\n\nQ = jnp.diag(jnp.array([10.0, 1.0])) # penalise angle more than rate\nR = jnp.array([[0.1]]) # control effort cost\n\nbuilder = jx.DiagramBuilder()\nplant = builder.add(LTISystem(A, B, C, D, name=\"pendulum\"))\ncontroller = builder.add(LinearQuadraticRegulator(A, B, Q, R, name=\"lqr\"))\n\nbuilder.connect(plant.output_ports[0], controller.input_ports[0])\nbuilder.connect(controller.output_ports[0], plant.input_ports[0])\n\ndiagram = builder.build()\ncontext = diagram.create_context()\n\n# Perturb the pendulum's initial angle by 15° (set one block's sub-state)\ncontext = context.with_subcontext(\n plant.system_id,\n context[plant.system_id].with_continuous_state(jnp.array([jnp.pi / 12, 0.0])),\n)\n\nresults = jx.simulate(\n diagram, context, (0.0, 5.0),\n recorded_signals={\"x\": plant.output_ports[0]},\n)\n```\n\n---\n\n### 3 · Differentiable Parameter Identification\n\n\n\n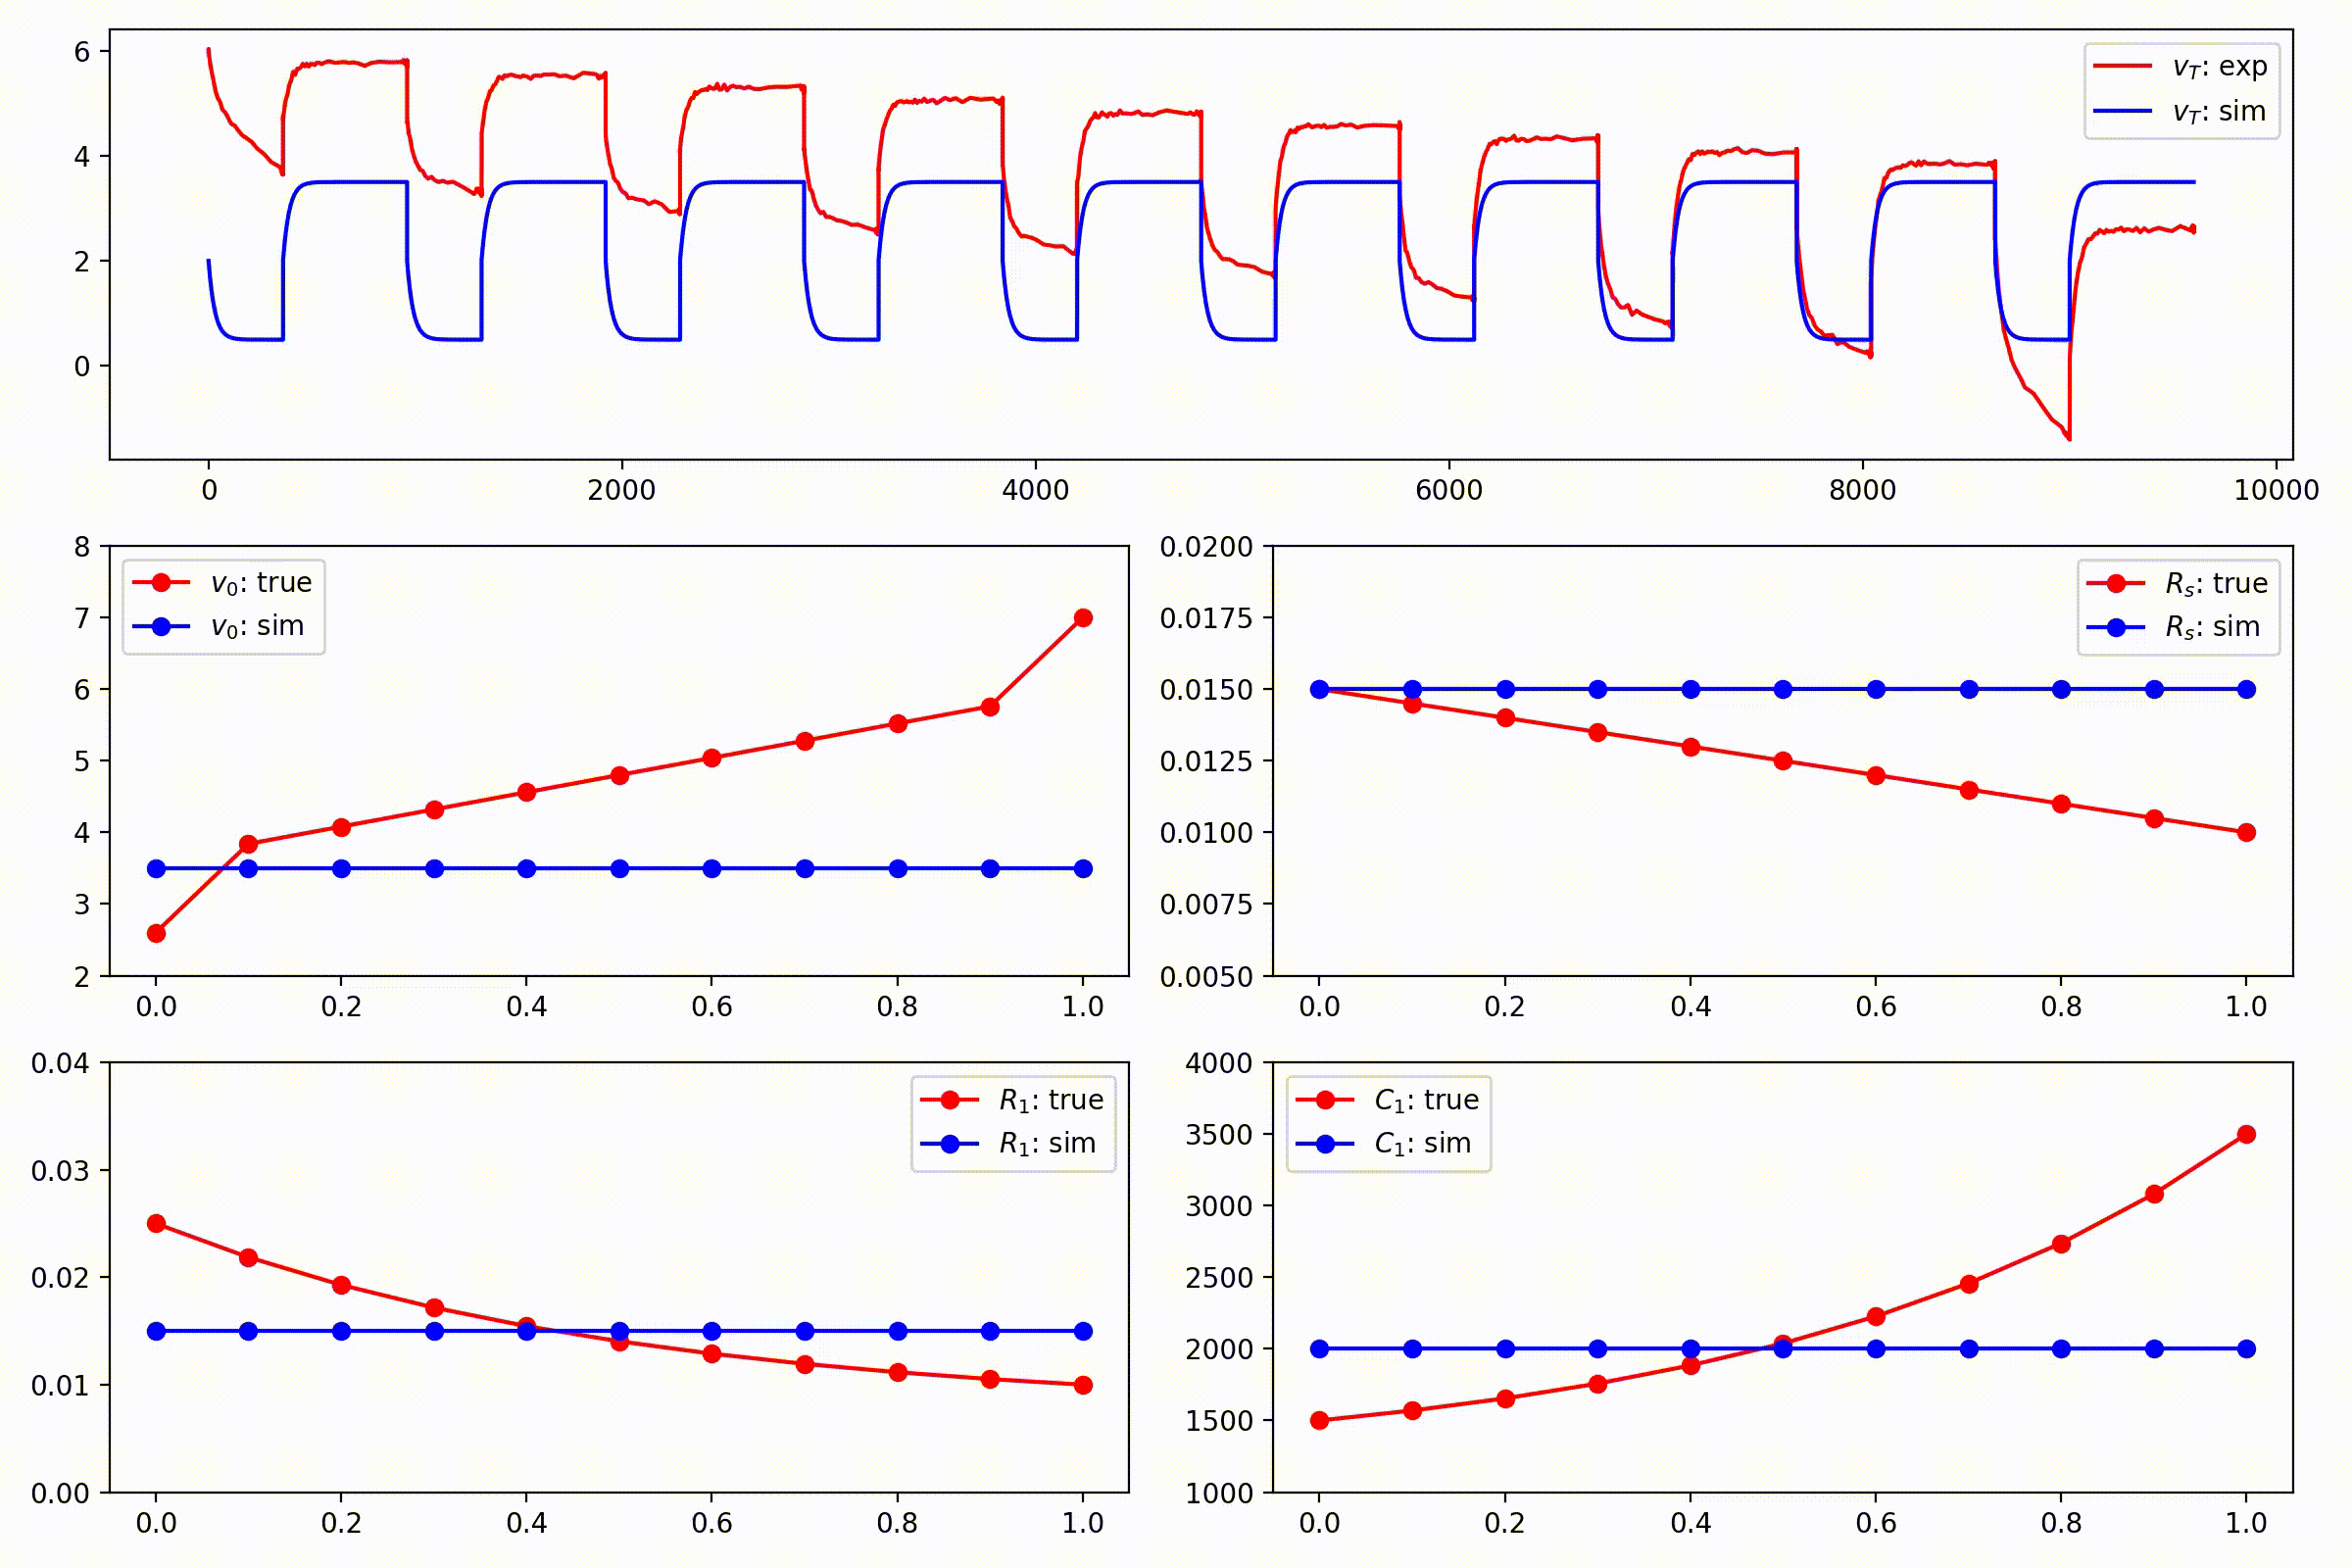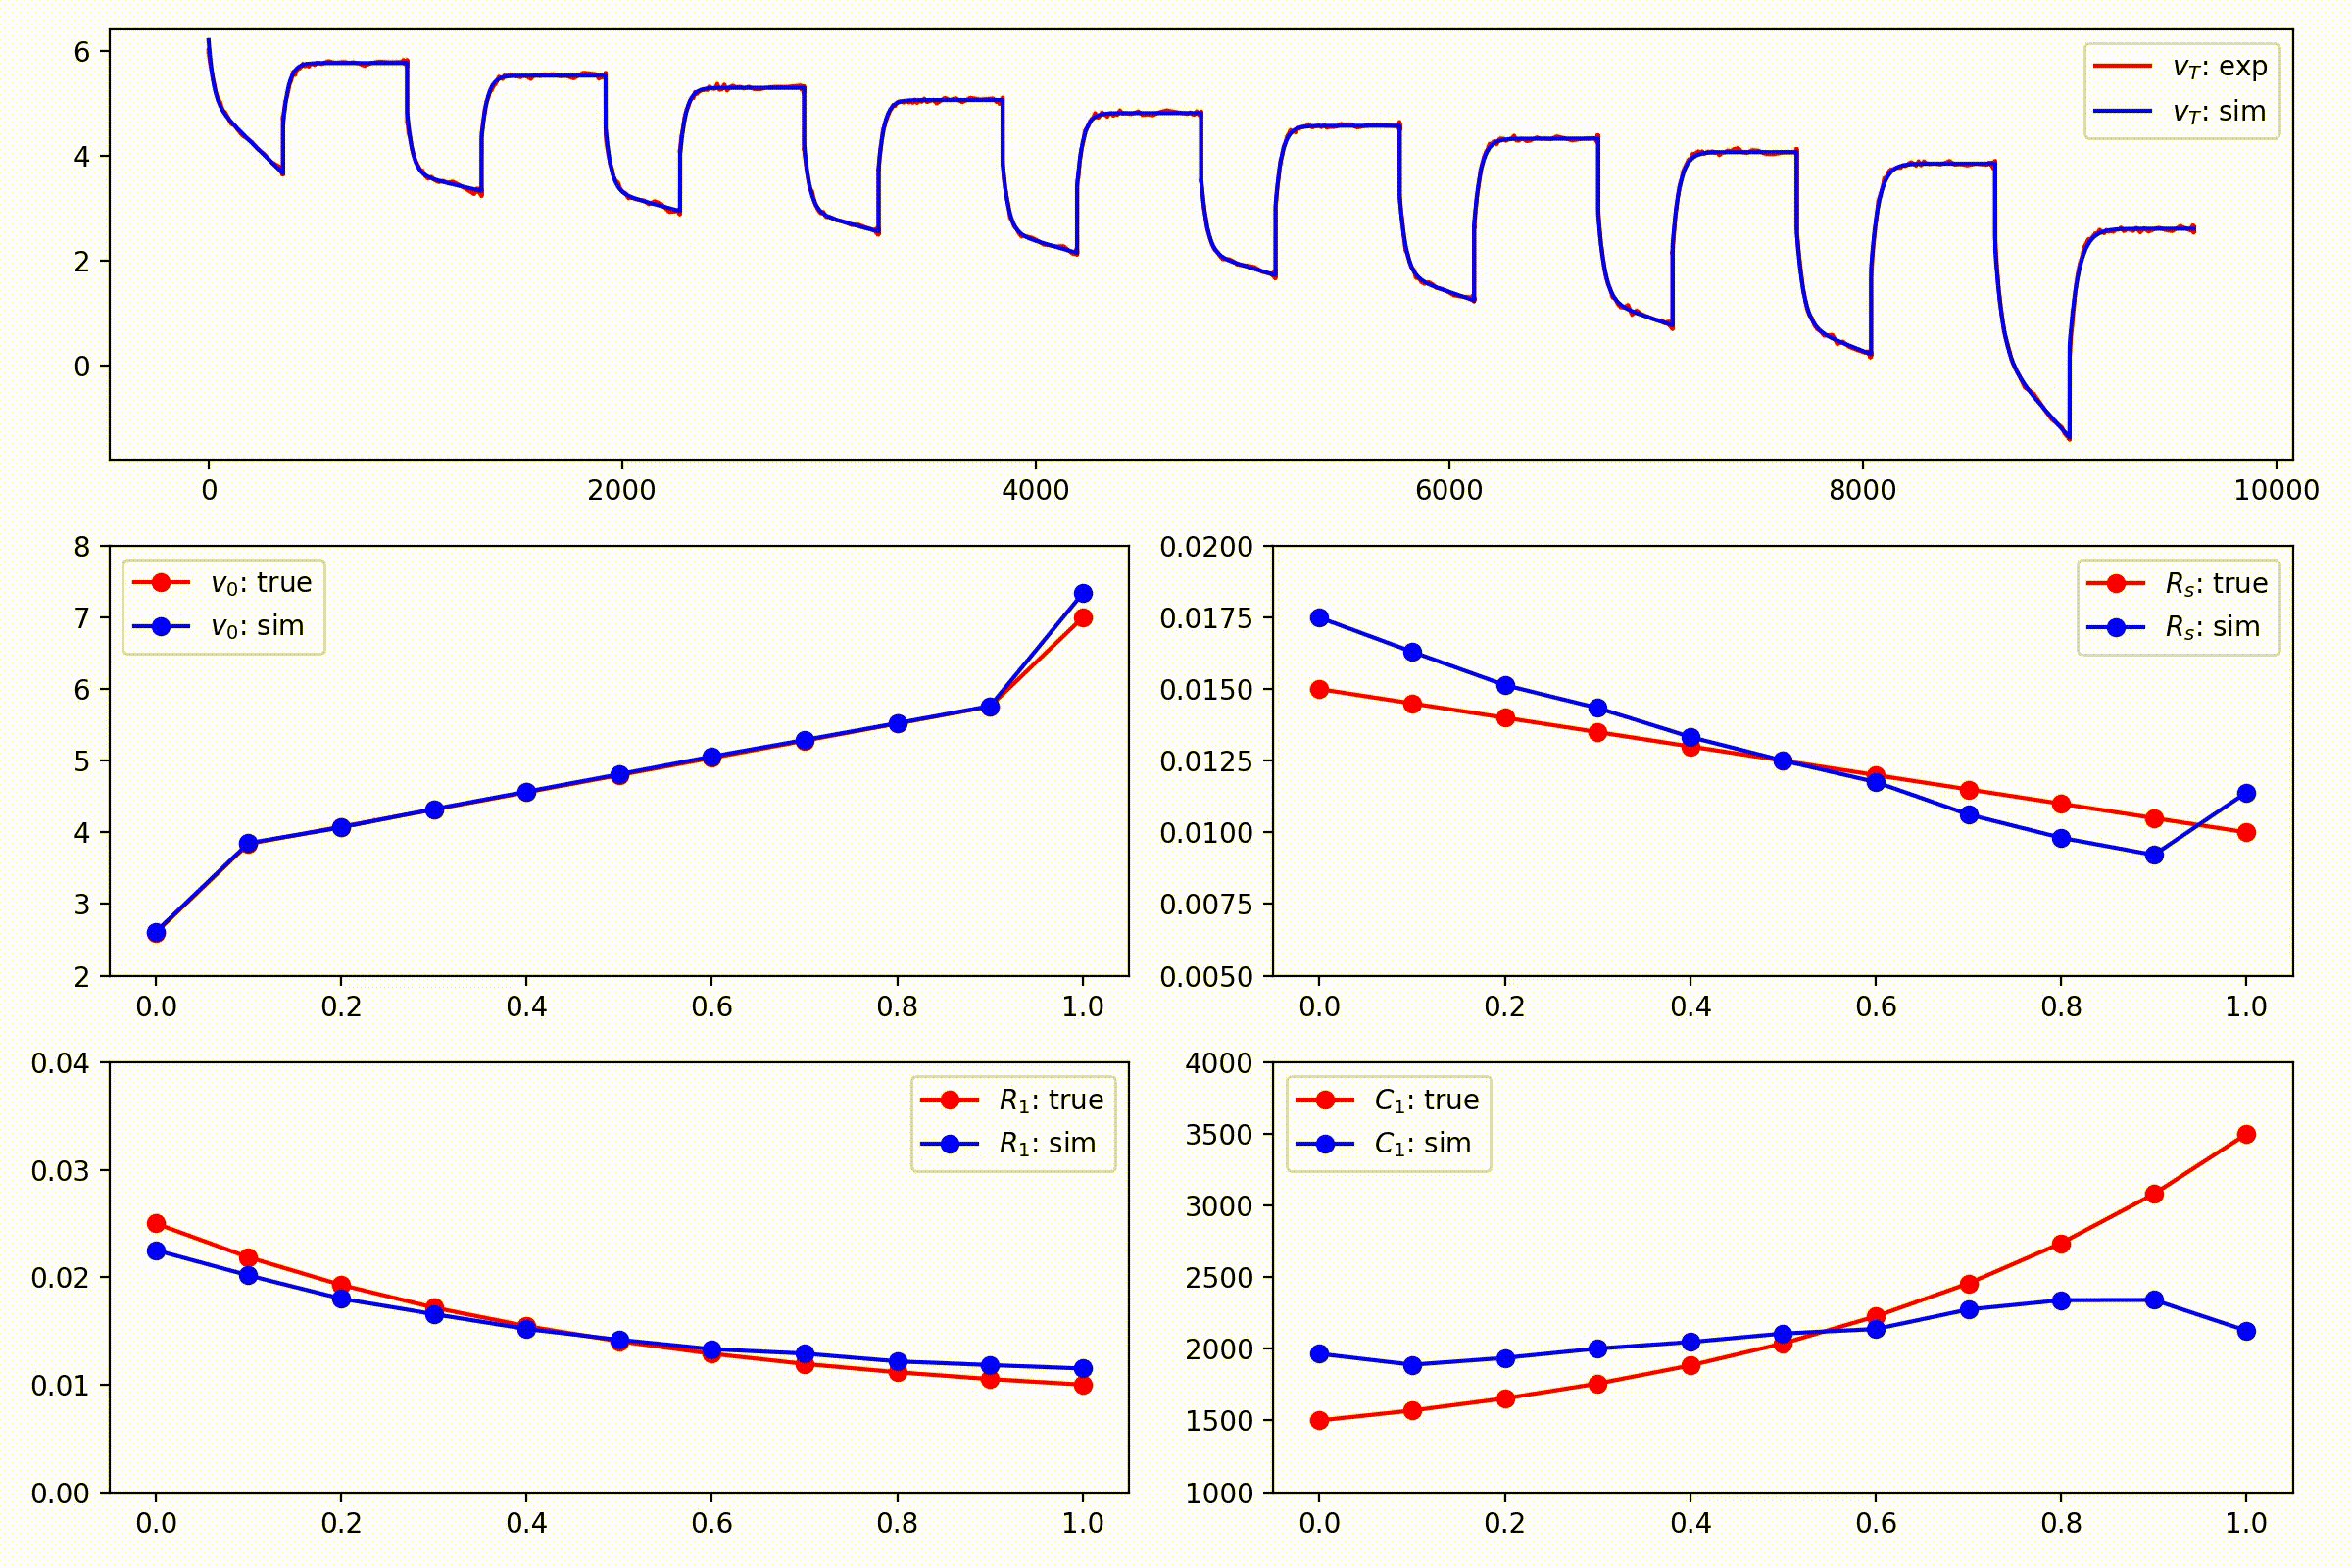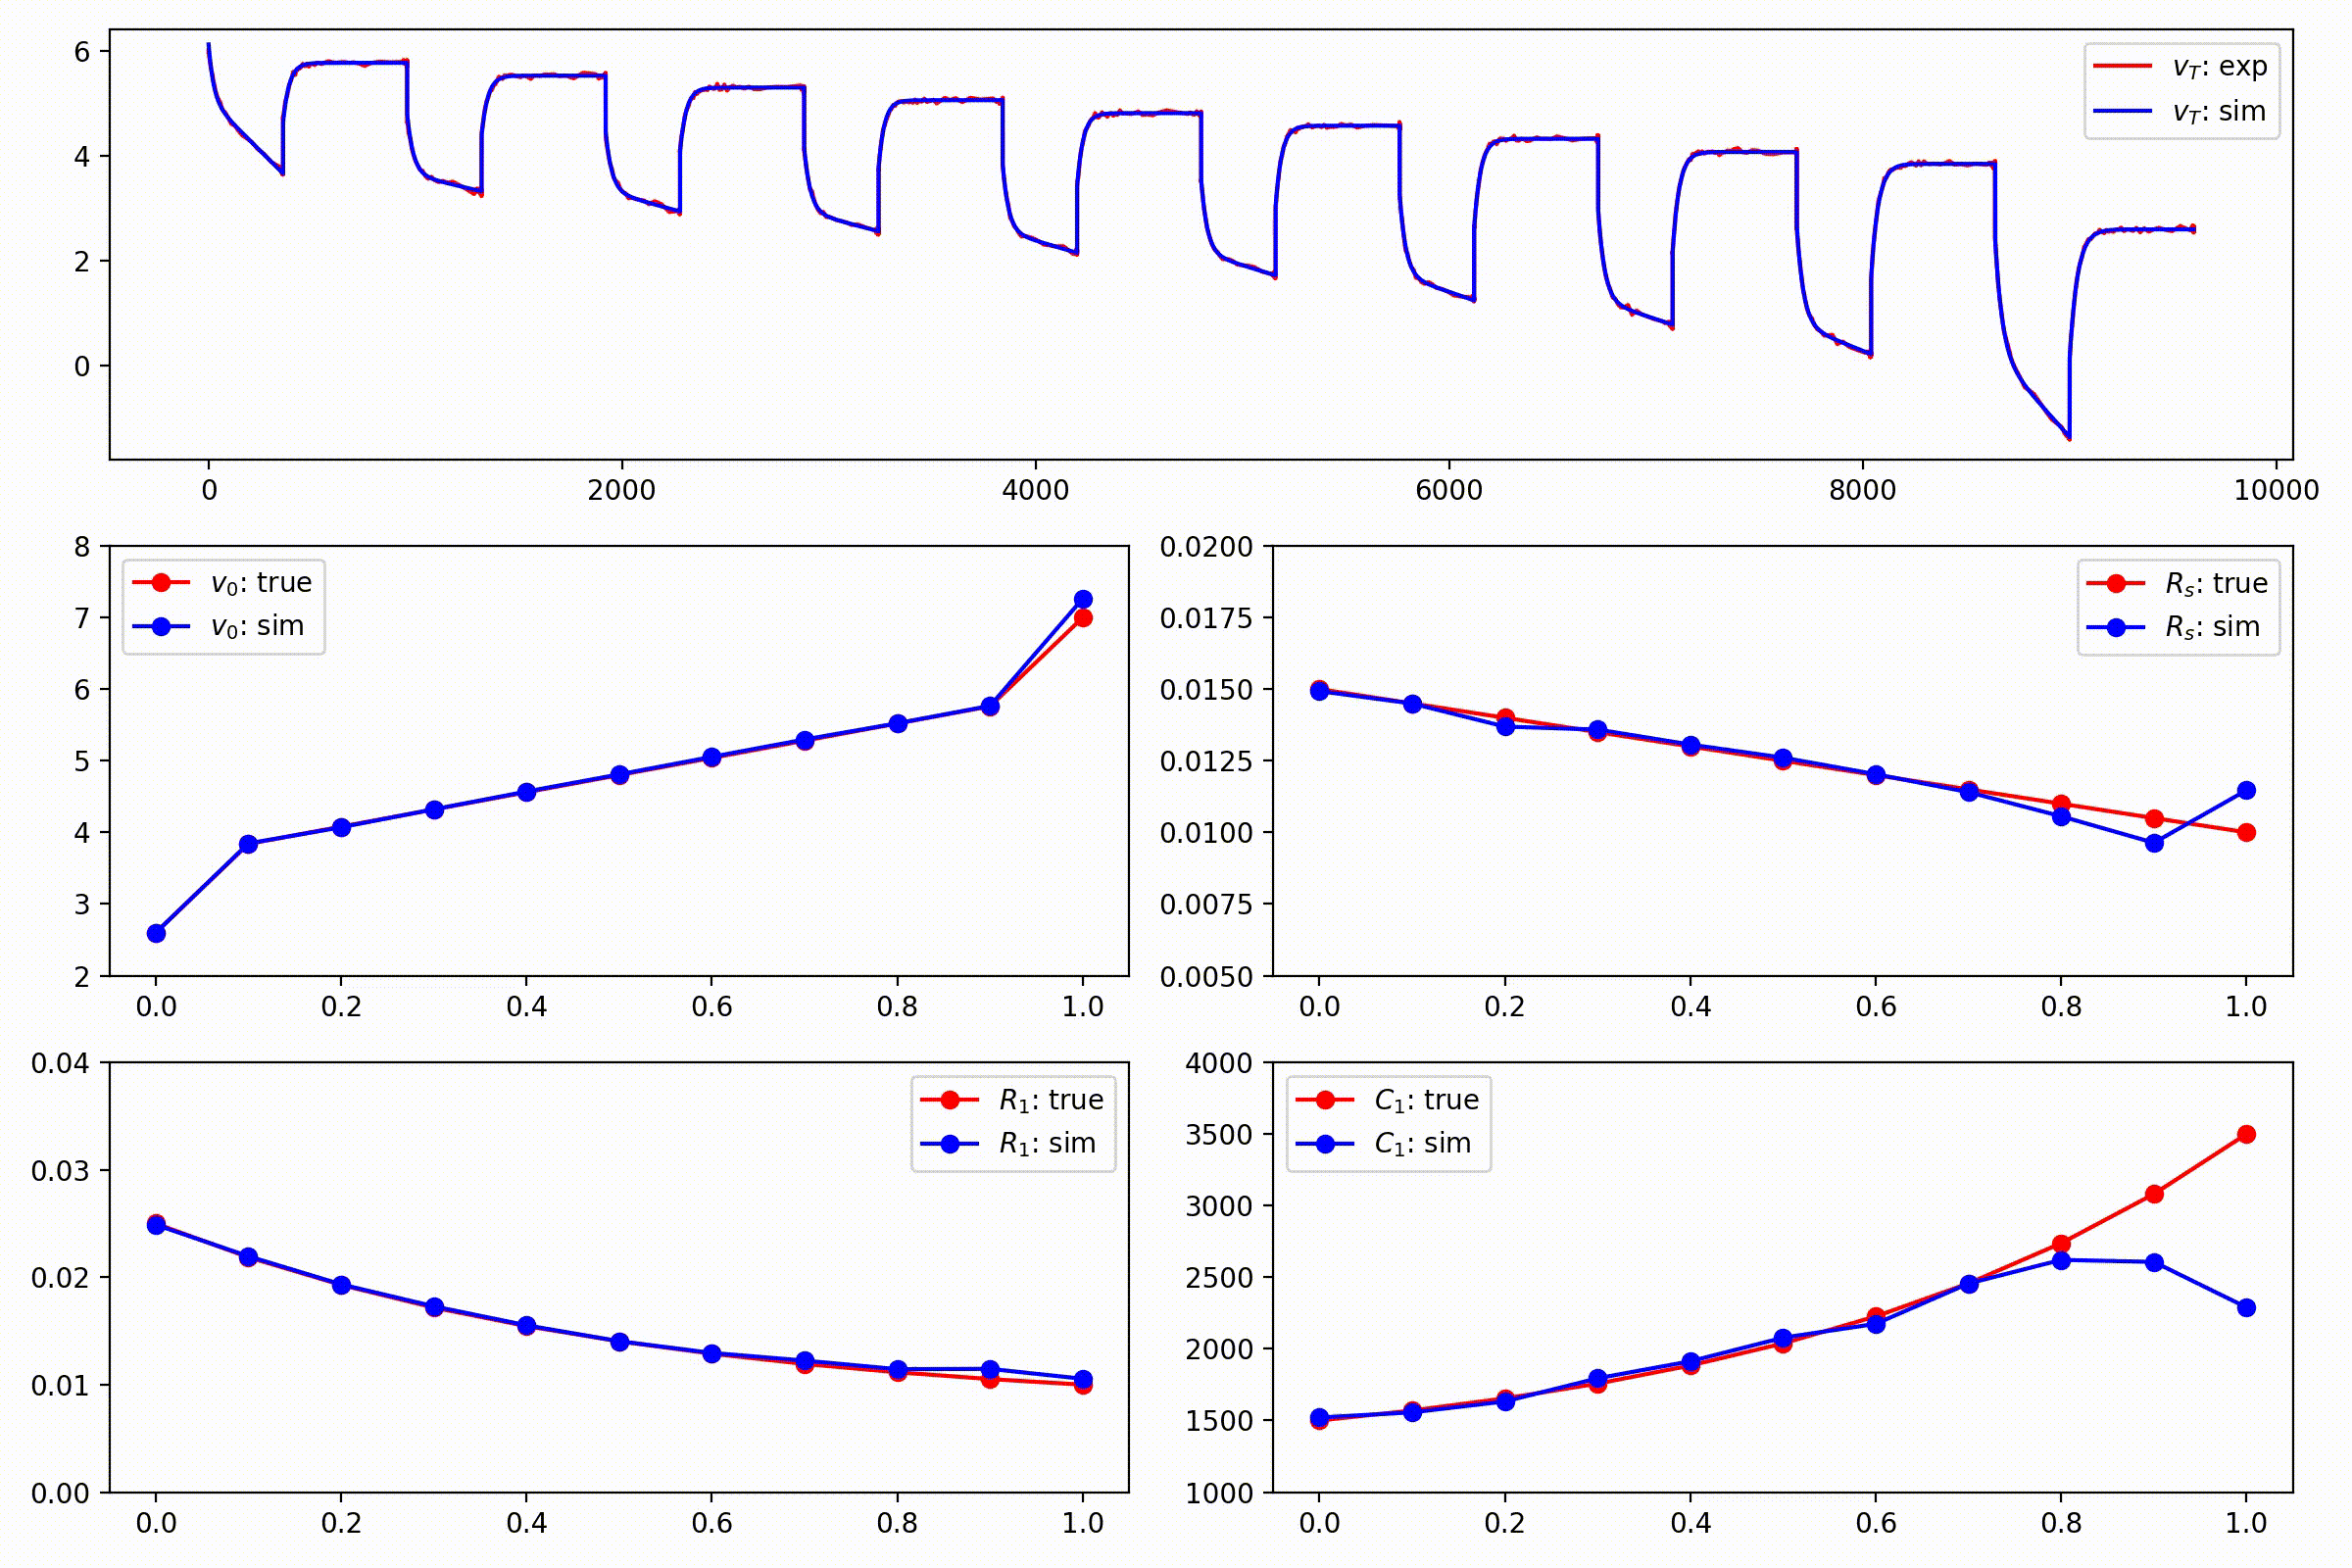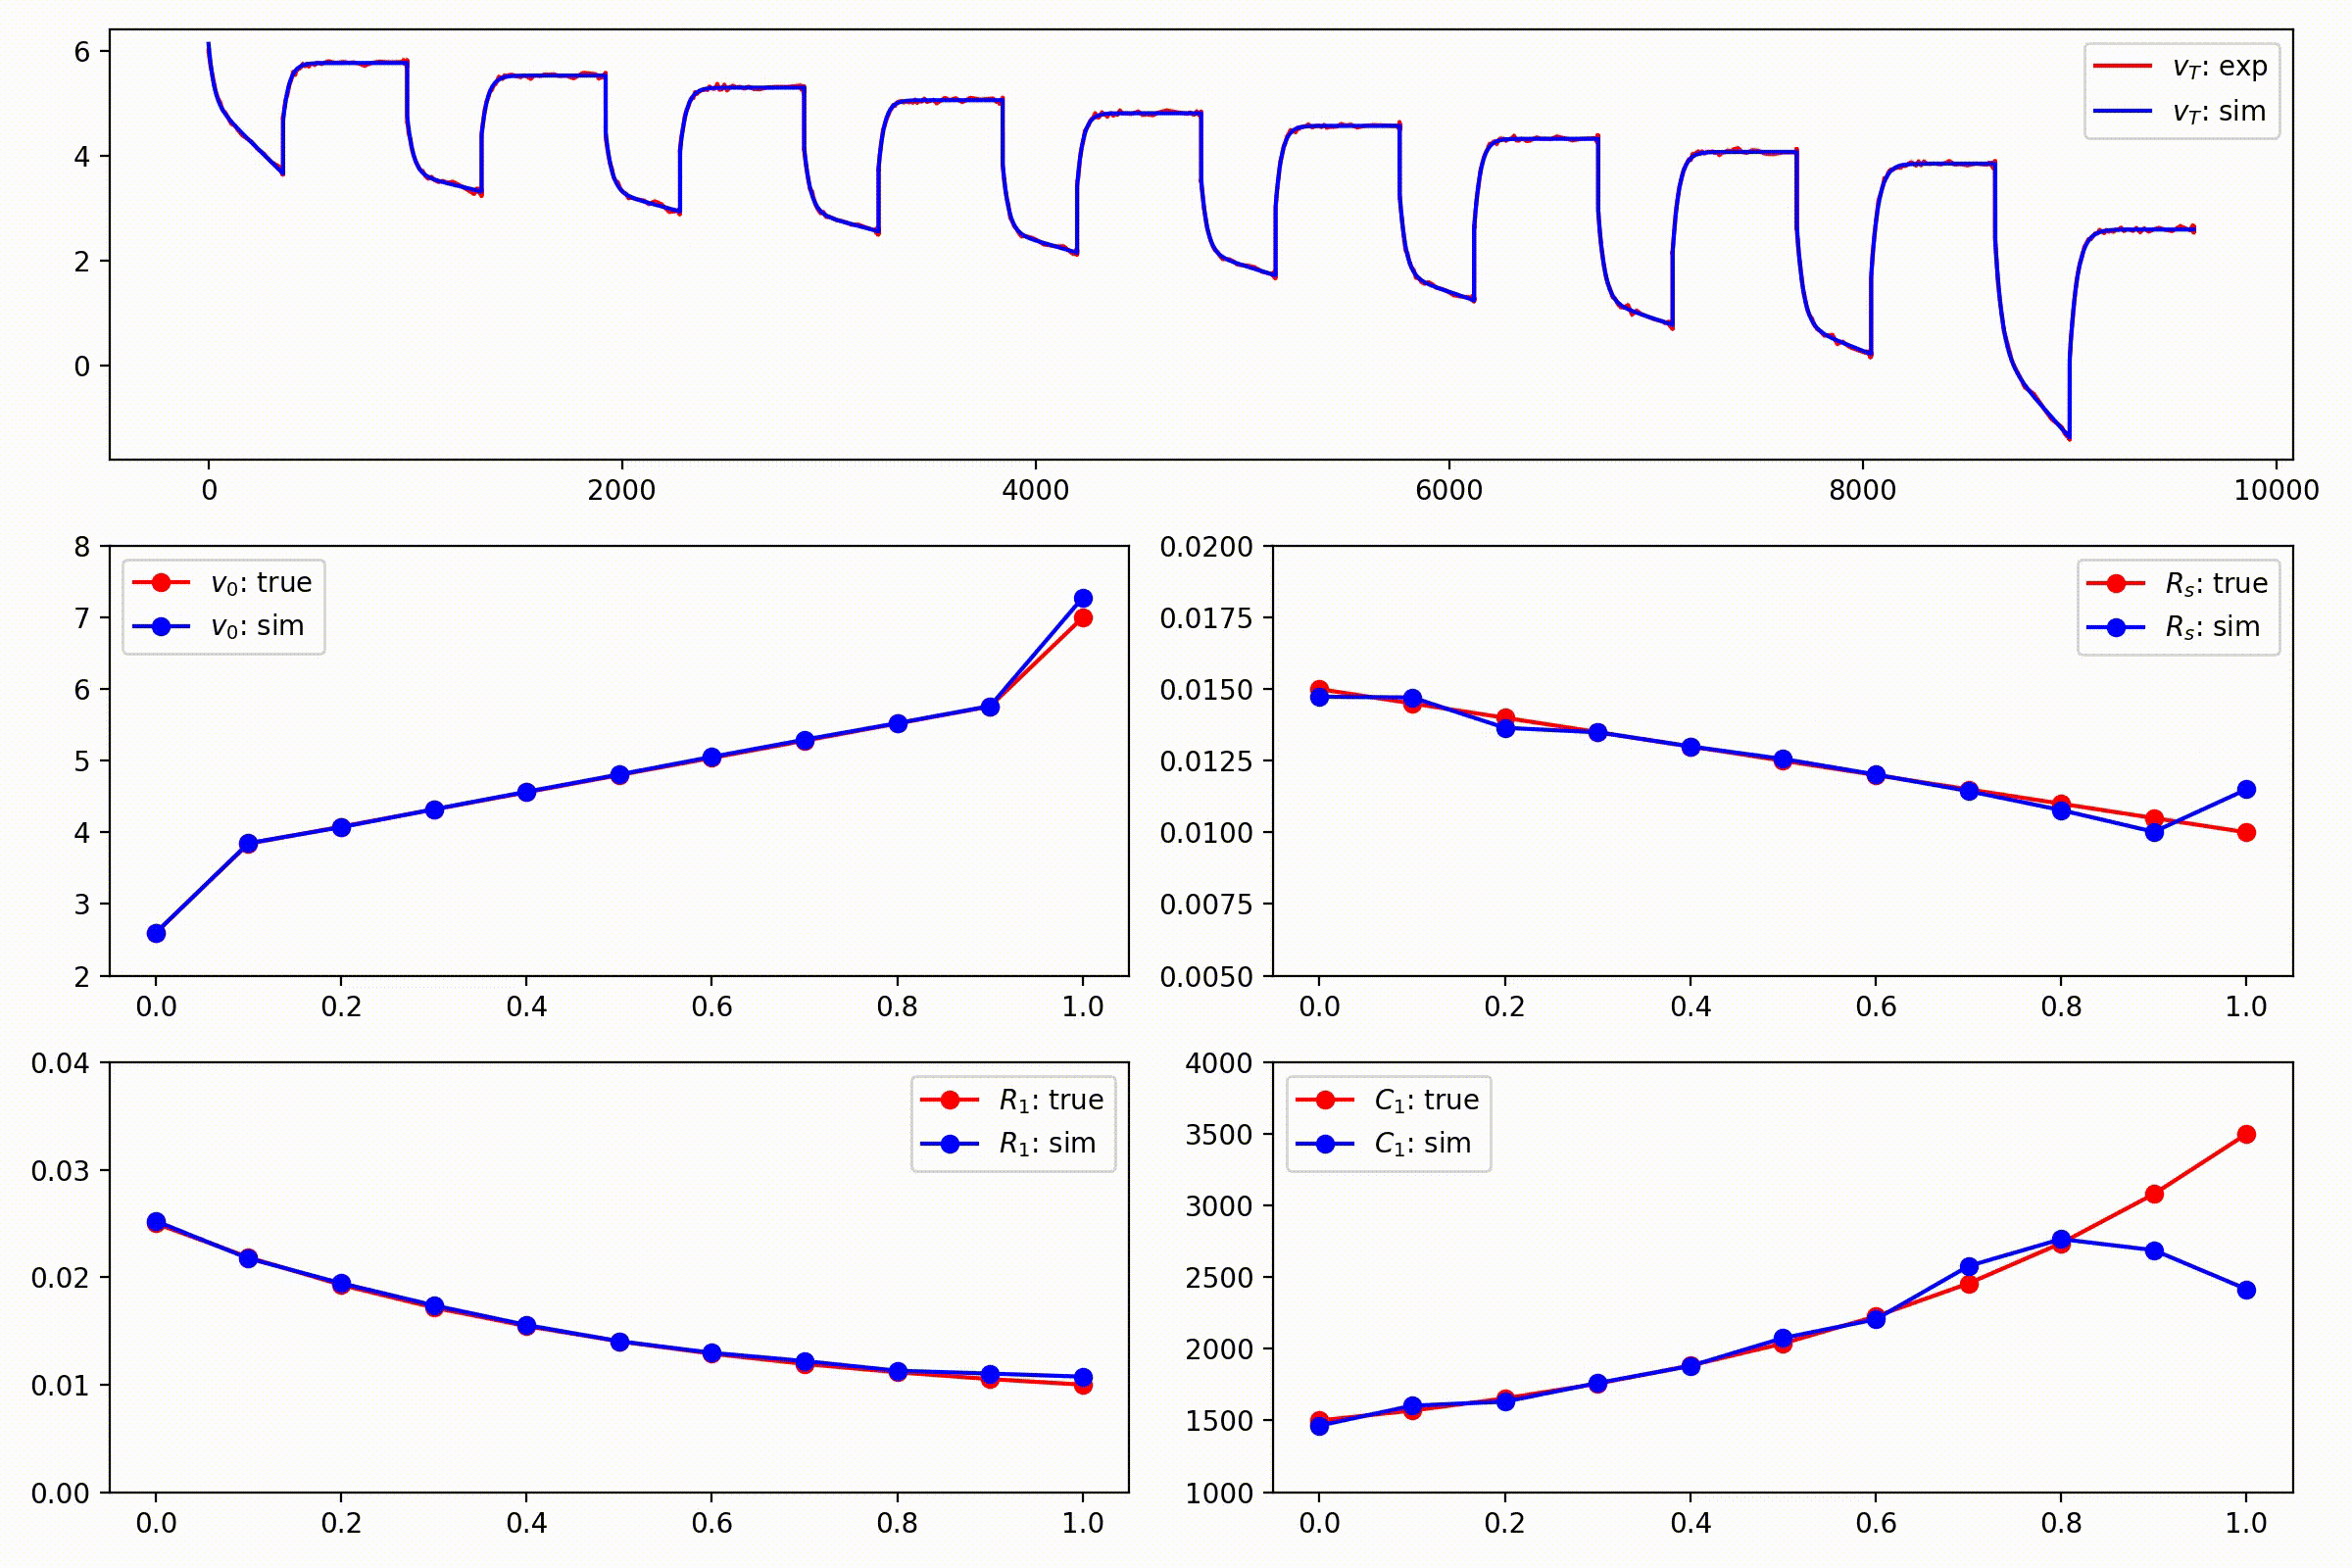\n\n
\n\nJaxonomy can **differentiate through complete simulations** to fit model parameters to data — no finite-difference approximations, no hand-written adjoint code. Here we recover a spring–damper's stiffness and damping by differentiating the whole rollout and descending with [Optax](https://optax.readthedocs.io):\n\n```python\nimport jax\nimport jax.numpy as jnp\nimport optax\nimport jaxonomy as jx\n\nclass SpringDamper(jx.LeafSystem):\n def __init__(self, k=1.0, c=0.3, **kwargs):\n super().__init__(**kwargs)\n self.declare_dynamic_parameter(\"k\", k)\n self.declare_dynamic_parameter(\"c\", c)\n self.declare_continuous_state(\n default_value=jnp.array([1.0, 0.0]), ode=self._ode\n )\n\n def _ode(self, time, state, *inputs, **params):\n x, v = state.continuous_state\n return jnp.array([v, -params[\"k\"] * x - params[\"c\"] * v])\n\nsd = SpringDamper(name=\"sd\")\nopts = jx.SimulatorOptions(enable_autodiff=True, max_major_steps=200)\n\ndef final_state(theta): # theta = {\"k\": ..., \"c\": ...}\n ctx = sd.create_context()\n ctx.parameters[\"k\"], ctx.parameters[\"c\"] = theta[\"k\"], theta[\"c\"]\n res = jx.simulate(sd, ctx, (0.0, 1.5), options=opts)\n return res.context.continuous_state # differentiable final [x, v]\n\ntarget = jax.lax.stop_gradient(final_state({\"k\": 4.0, \"c\": 0.5})) # \"measured\"\nloss = lambda theta: jnp.sum((final_state(theta) - target) ** 2)\n\ntheta = {\"k\": 1.0, \"c\": 0.1}\nopt = optax.adam(2e-1)\nstate = opt.init(theta)\ngrad_fn = jax.jit(jax.grad(loss)) # gradient through the ODE solver\nfor _ in range(300):\n updates, state = opt.update(grad_fn(theta), state)\n theta = optax.apply_updates(theta, updates)\n# theta → {\"k\": 4.00, \"c\": 0.50}\n```\n\n`jax.grad(loss)` flows back through every ODE step automatically, so the same recipe scales to battery ECMs (above), powertrains, or any parametric model — and `jaxonomy.optimization` wraps it in a higher-level `Optimizable` API when you want bounds, transforms, and constraints.\n\n---\n\n### 4 · Acausal Physical Modeling\n\n\n\n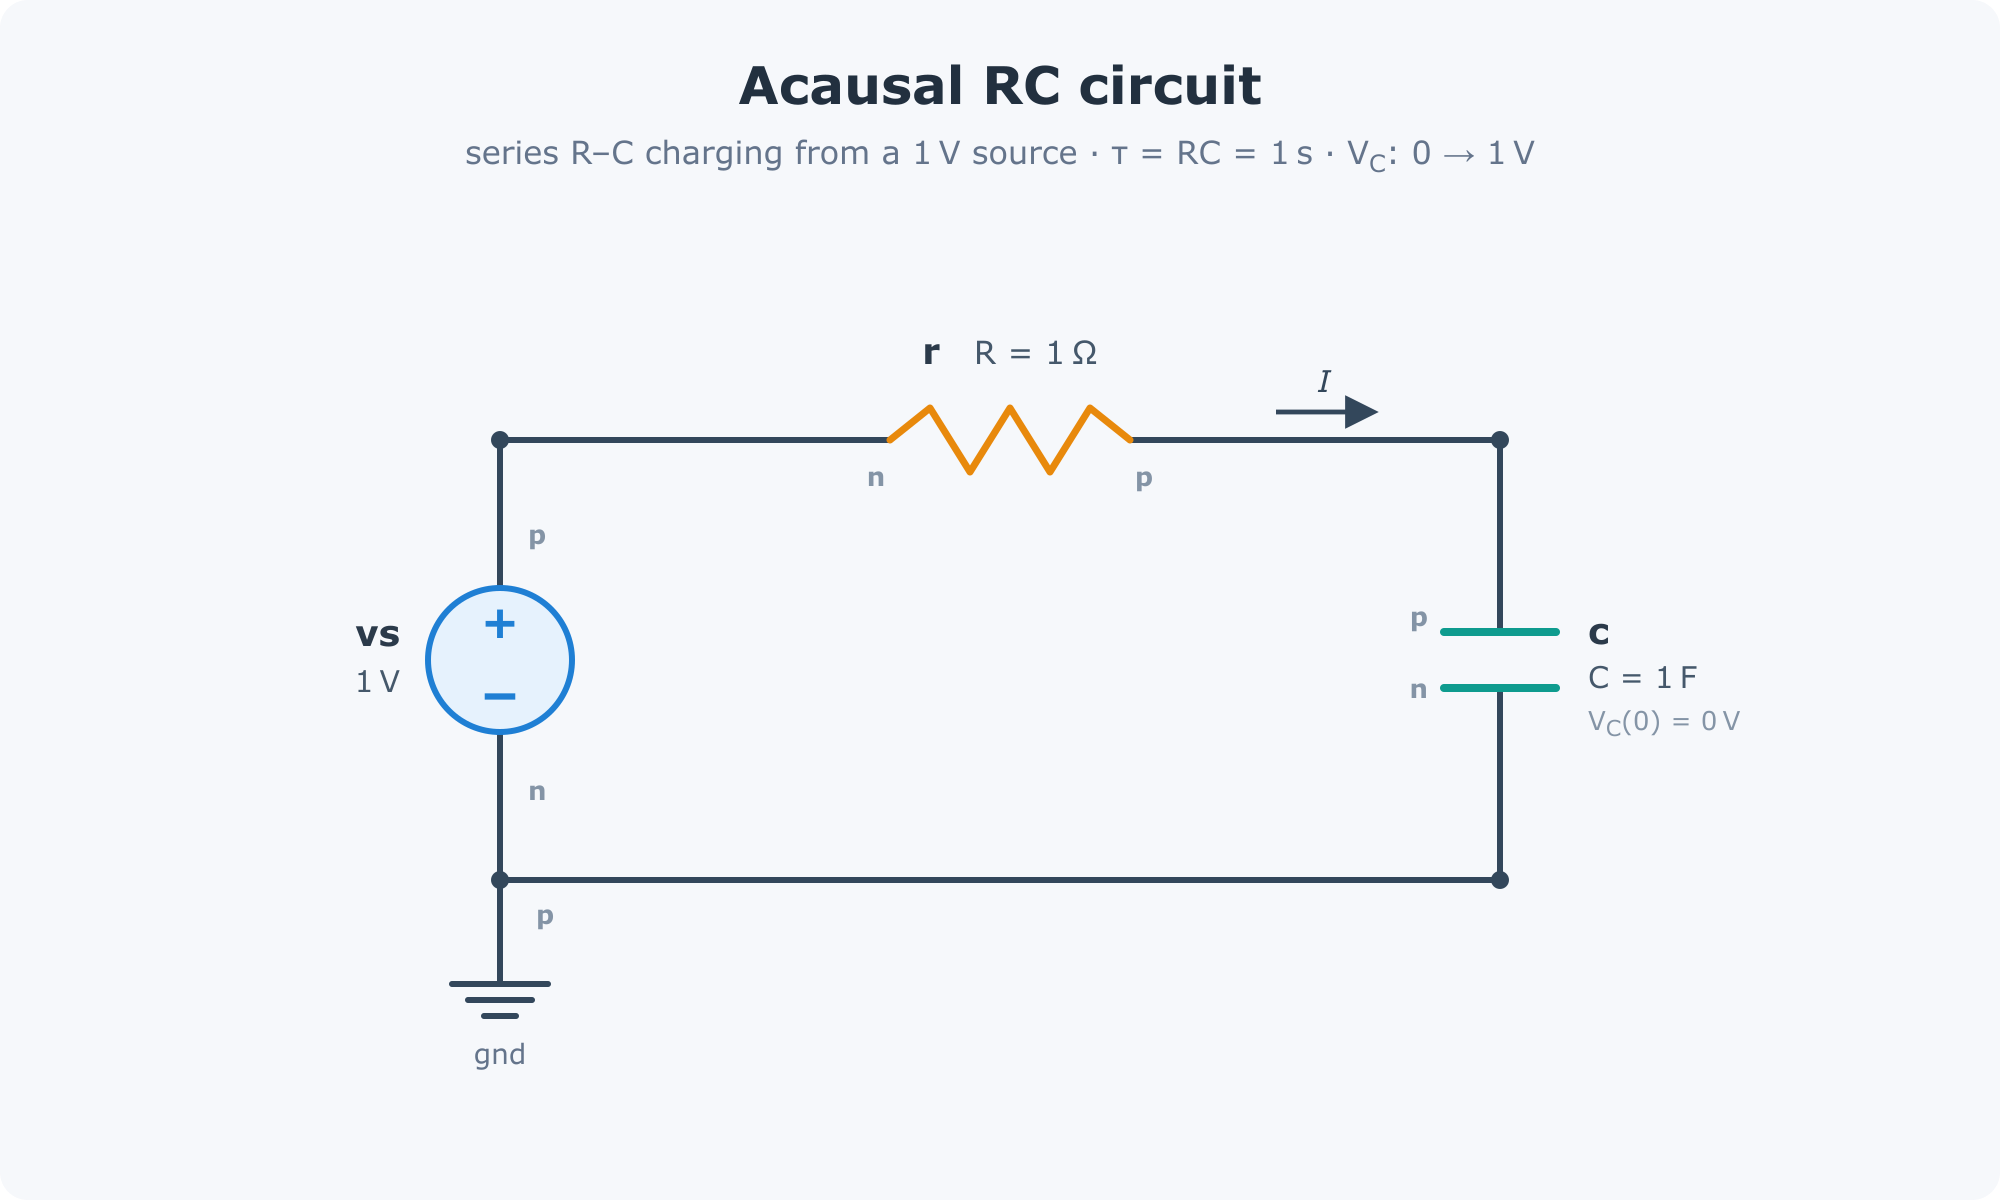\n\n
\n\nJaxonomy includes a Modelica-inspired **acausal modeling layer** for multi-domain physical systems. You describe component connections symbolically; the compiler automatically derives the governing DAE, reduces its index, and emits a `LeafSystem` ready to drop into any diagram.\n\n**RC circuit with initial conditions:**\n\n$$\nC\\,\\dot{V}_C = I, \\qquad V_C(0) = 0\\,\\text{V}, \\qquad V_{\\text{src}} = 1\\,\\text{V}\n$$\n\n```python\nimport jaxonomy as jx\nfrom jaxonomy.acausal import AcausalCompiler, AcausalDiagram, EqnEnv\nfrom jaxonomy.acausal import electrical as elec\n\nev = EqnEnv()\nad = AcausalDiagram()\n\nvs = elec.VoltageSource(ev, name=\"vs\", v=1.0)\nr = elec.Resistor(ev, name=\"r\", R=1.0)\nc = elec.Capacitor(ev, name=\"c\", C=1.0,\n initial_voltage=0.0, initial_voltage_fixed=True)\ngnd = elec.Ground(ev, name=\"gnd\")\n\nad.connect(vs, \"p\", r, \"n\")\nad.connect(r, \"p\", c, \"p\")\nad.connect(c, \"n\", vs, \"n\")\nad.connect(vs, \"n\", gnd, \"p\")\n\ncompiler = AcausalCompiler(ev, ad)\nrc_block = compiler() # → LeafSystem, JIT-compiled ODE\n\nbuilder = jx.DiagramBuilder()\nrc = builder.add(rc_block)\ndiagram = builder.build()\nresults = jx.simulate(\n diagram,\n diagram.create_context(),\n (0.0, 5.0),\n recorded_signals={\"rc\": rc.output_ports[0]},\n)\n\nresults.outputs[\"rc\"] # capacitor charges 0 → 0.993 V over 5 τ (R = C = 1)\n```\n\nThe same pipeline handles **multi-domain systems** — an electro-mechanical actuator connecting `electrical`, `rotational`, and `translational` domains compiles to a single optimized system.\n\nAvailable acausal domains: `electrical` · `rotational` · `translational` · `thermal` · `fluid`\n\n---\n\n### 5 · Differentiable Sensitivity & Batch Simulation\n\n\n\n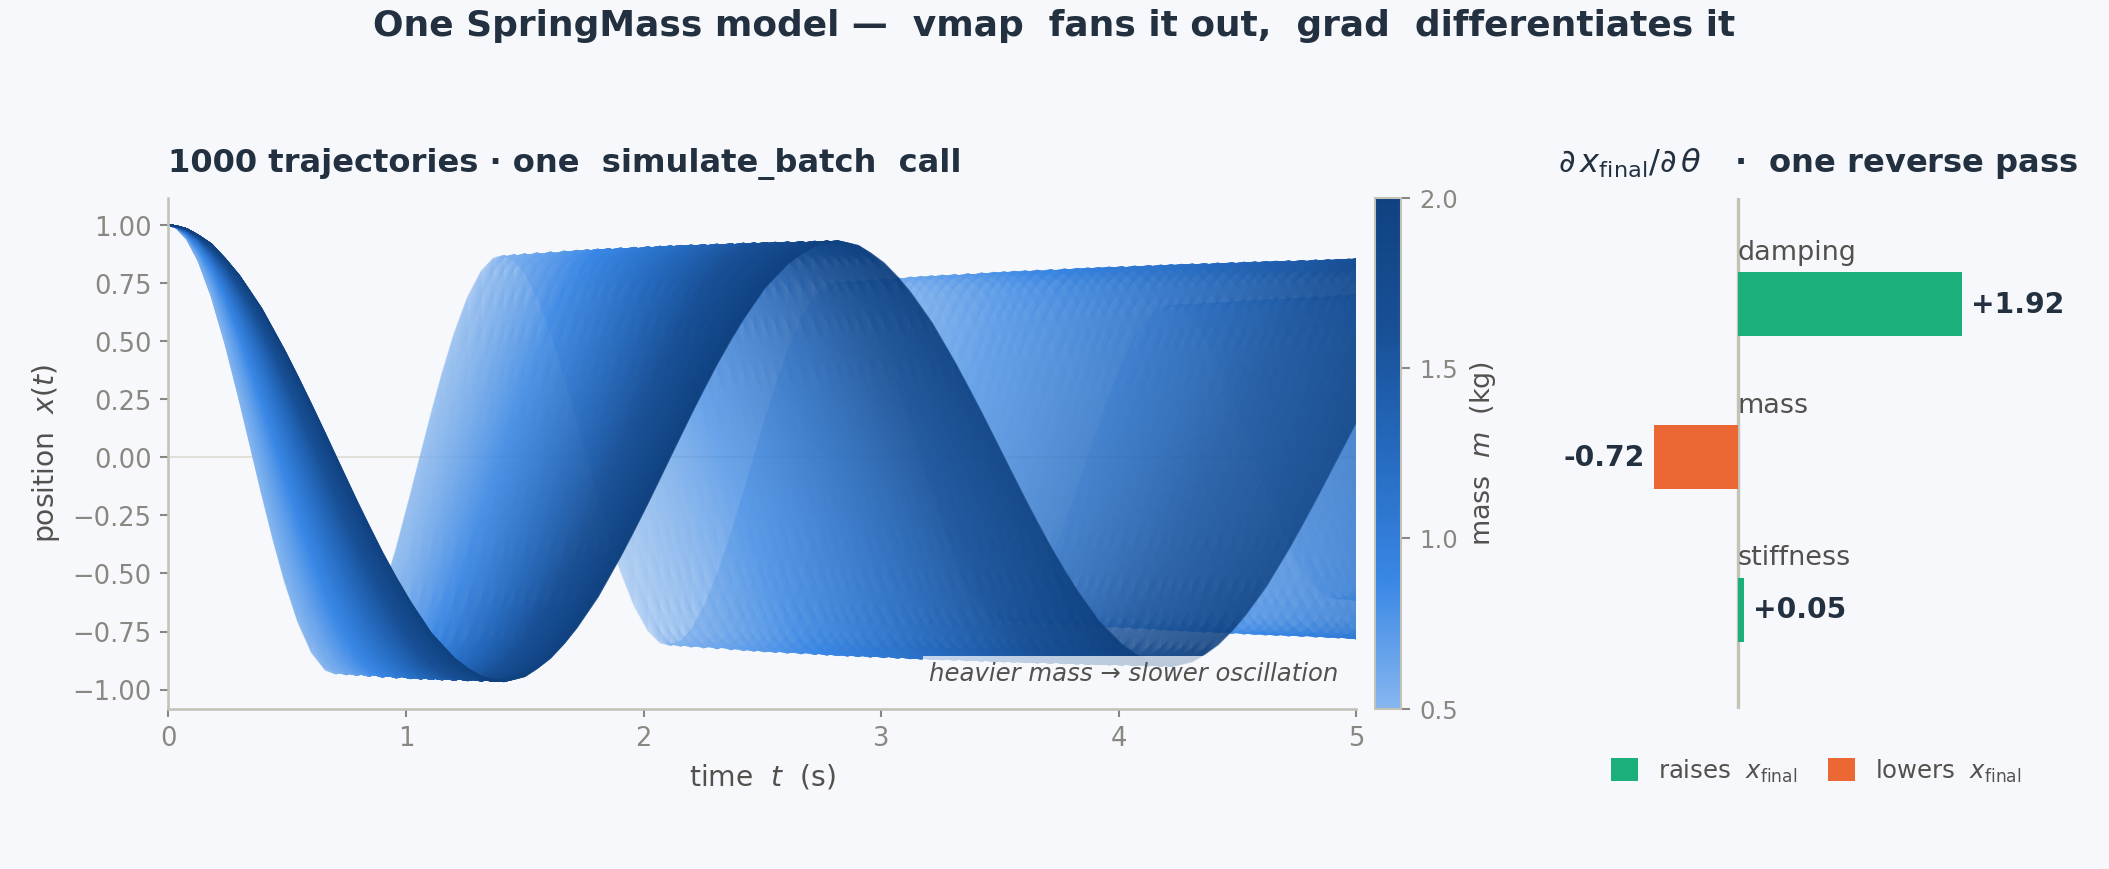\n\n
\n\nBecause `jax.grad`, `jax.jit`, and `jax.vmap` all compose with `simulate`, you get powerful workflows with minimal boilerplate:\n\n```python\nimport jax\nimport jax.numpy as jnp\nimport jaxonomy as jx\n\nclass SpringMass(jx.LeafSystem):\n def __init__(self, mass=1.0, damping=0.1, stiffness=10.0, **kwargs):\n super().__init__(**kwargs)\n self.declare_dynamic_parameter(\"mass\", mass)\n self.declare_dynamic_parameter(\"damping\", damping)\n self.declare_dynamic_parameter(\"stiffness\", stiffness)\n self.declare_continuous_state(\n default_value=jnp.array([1.0, 0.0]), ode=self._ode\n )\n self.declare_continuous_state_output(name=\"x\")\n\n def _ode(self, time, state, *inputs, **params):\n x, v = state.continuous_state\n a = -(params[\"stiffness\"] * x + params[\"damping\"] * v) / params[\"mass\"]\n return jnp.array([v, a])\n\n# ── Sensitivity: ∂(final position)/∂(all parameters) in one reverse pass ─────\nplant = SpringMass(name=\"plant\")\ngrad_opts = jx.SimulatorOptions(enable_autodiff=True, max_major_steps=200)\n\ndef final_position(theta):\n ctx = plant.create_context()\n for name, value in theta.items():\n ctx.parameters[name] = value\n res = jx.simulate(plant, ctx, (0.0, 5.0), options=grad_opts)\n return res.context.continuous_state[0]\n\ngrads = jax.grad(final_position)({\"mass\": 1.0, \"damping\": 0.1, \"stiffness\": 10.0})\n\n# ── Monte Carlo ensemble: 1000 trajectories over a mass sweep (vmap) ─────────\nbuilder = jx.DiagramBuilder()\nplant_b = builder.add(SpringMass(name=\"plant\"))\ndiagram = builder.build()\n\nresults = jx.simulate_batch(\n diagram, t_span=(0.0, 5.0),\n param_batches={\"plant.mass\": jnp.linspace(0.5, 2.0, 1000)},\n options=jx.SimulatorOptions(math_backend=\"jax\", max_major_steps=200),\n recorded_signals={\"x\": plant_b.output_ports[0]},\n)\n# results.outputs[\"x\"] shape: (1000, T, 2)\n```\n\n---\n\n## 🧩 Library Overview\n\nOver **150 built-in blocks** covering the full signal-processing and control toolkit. A representative slice — not exhaustive:\n\n| Category | Blocks |\n|---|---|\n| **Sources** | `Constant`, `Step`, `Ramp`, `Chirp`, `Pulse`, `Sawtooth`, `Clock`, `DataSource` |\n| **Stochastic** | `RandomNumber`, `UniformRandomNumber`, `WhiteNoise`, `BandLimitedNoise`, `PRBS`, `RandomSource` — all support `with_key` for independent noise streams under `vmap` |\n| **Arithmetic & nonlinearities** | `Adder`, `Gain`, `Product`, `Abs`, `Power`, `Trigonometric`, `Saturate` / `SoftSaturate`, `DeadZone`, `RateLimiter` / `SoftRateLimiter`, `Quantizer`, `Backlash` |\n| **Continuous dynamics** | `Integrator`, `Derivative`, `TransferFunction`, `LTISystem`, `PID` / `PIDContinuous` |\n| **Discrete dynamics** | `IntegratorDiscrete`, `UnitDelay`, `FilterDiscrete`, `LowPassDiscrete`, `LeadLag`, `Notch`, `PIDDiscrete`, `PIDController2DOF`, `Decimator`, `RateTransition` |\n| **Routing, buses, matrix** | `Mux` / `Demux`, `BusCreator` / `BusSelector` / `BusUpdate` (with `BusUnit` annotations), `Slice`, `Stack`, `Switch` / `MultiPortSwitch`, `IfThenElse`, `MatrixMultiplication`, `MatrixInversion`, `DotProduct`, `CrossProduct` |\n| **Logic & state machines** | `TruthTable`, `LogicalOperator`, `Comparator`, `Relay`, `EdgeDetection`, `StateMachine` (authored via `StateMachineBuilder` DSL) |\n| **Lookup tables** | `LookupTable1d` / `LookupTable2d` / `LookupTableND`, `Prelookup` / `InterpolationUsingPrelookup`, `TableSearch` — all differentiable and fittable from data via `fit_lookup_table_*` |\n| **Delays & containers** | `TransportDelay`, `VariableTransportDelay`, `EnabledSubsystem`, `TriggeredSubsystem`, `ForEach`, `Conditional` |\n| **Control** | `LinearQuadraticRegulator` / `DiscreteTimeLinearQuadraticRegulator` / `FiniteHorizonLinearQuadraticRegulator` / `LinearQuadraticGaussian`, `LinearDiscreteTimeMPC` (native + `LinearDiscreteTimeMPC_OSQP`), `DirectShootingNMPC` / `DirectTranscriptionNMPC` / `HermiteSimpsonNMPC` |\n| **Estimation** | `KalmanFilter`, `ExtendedKalmanFilter`, `UnscentedKalmanFilter`, `InfiniteHorizonKalmanFilter`, `RecursiveLeastSquares`, `AugmentedStateEKF`, `Luenberger` |\n| **Physics & coordinates** | `CoordinateRotation`, `RigidBody`, `BatteryCell` |\n| **ML / Data** | `MLP` (Equinox), `Sindy`, `PyTorch`, `TensorFlow`, `ONNX` / `ONNXJax` |\n| **ROM & surrogates** | `reduce(...)` → `ReducedOrderModel`; linear MOR (`balred` / `minreal` / `modal_truncation` / `residualize`), `galerkin_reduce` + `deim` (POD–DEIM), `dmd` / `dmdc` / `era`, `DMDForecaster` / `KoopmanPredictor`, and surrogate blocks `GaussianProcess` / `PolynomialChaos` / `RadialBasisSurrogate` |\n| **Interop** | `ModelicaFMU` / `ModelicaFMUME` (FMI 2.0 / 3.0 co-simulation and model-exchange import) + FMU export via `build_fmu`; `MuJoCo` / `MJX`; `Ros2Publisher` / `Ros2Subscriber`; `QuanserHAL`; `PyTwin` |\n| **Custom** | `CustomPythonBlock`, `CustomJaxBlock` for user-authored algorithms with persistent per-instance state |\n\nCustom blocks are first-class beyond the wrappers above: subclass `LeafSystem`, declare ports and states, and your block integrates with the full framework including JIT, autodiff, and event detection.\n\n---\n\n## 🏗️ System Architecture\n\nA Jaxonomy model is a **Diagram** — a directed graph of interconnected blocks. Blocks (`LeafSystem`) declare ports, continuous/discrete states, and event guards. The simulator orchestrates ODE integration, discrete updates, and event detection automatically.\n\n```mermaid\ngraph LR\n subgraph Diagram[\"DiagramBuilder.build()\"]\n direction LR\n r[/\"r(t)\\nReference\"/] --> sum((\"Σ\"))\n sum -->|\"e(t)\"| ctrl[\"Controller\\nLQR · MPC · PID\"]\n ctrl -->|\"u(t)\"| plant[\"Plant\\nLTI · Nonlinear · Acausal\"]\n plant -->|\"x(t)\"| obs[\"State Estimator\\nKalman · EKF · UKF\"]\n obs --> sum\n plant -->|\"y(t)\"| out[/\"y(t)\\nOutput\"/]\n end\n\n style Diagram fill:#f5f8ff,stroke:#4a6fa5,stroke-width:2px\n style ctrl fill:#dbeafe,stroke:#2563eb\n style plant fill:#dcfce7,stroke:#16a34a\n style obs fill:#fef9c3,stroke:#ca8a04\n```\n\nThe JAX backend sits underneath every simulation, giving you a clean Python API backed by XLA compilation:\n\n```mermaid\ngraph TD\n A[\"Python API\\nDiagram · LeafSystem · simulate()\"] --> B[\"JAX Backend\\nJIT · vmap · grad\"]\n B --> C1[\"Dopri5\\nAdaptive RK45\\nnon-stiff ODEs\"]\n B --> C2[\"BDF\\nImplicit solver\\nstiff systems\"]\n B --> C3[\"Event Handler\\nZero-crossing\\nbisection\"]\n\n style A fill:#e0f2fe,stroke:#0284c7\n style B fill:#fdf4ff,stroke:#9333ea\n style C1 fill:#f0fdf4,stroke:#16a34a\n style C2 fill:#f0fdf4,stroke:#16a34a\n style C3 fill:#f0fdf4,stroke:#16a34a\n```\n\n---\n\n## The Jaxonomy stack\n\nJaxonomy is the engine at the base of a three-package stack. Each package is its\nown repository, MIT-licensed, and depends only on the package(s) above it:\n\n- **Jaxonomy** — *this package.* The general-purpose, JAX-native simulation\n engine for hybrid dynamical systems. Not robotics-specific; depends on nothing\n else in the stack.\n- **[Jaxterity](https://github.com/machinavitalis/jaxterity)** — the robotics\n layer built on top of Jaxonomy: URDF/MJCF import, MJX-backed articulated\n dynamics, calibrated actuators/sensors, system identification, and whole-body\n control. Imports Jaxonomy; never re-implements its primitives.\n- **[Jaxility](https://github.com/machinavitalis/jaxility)** — the deployment\n artifact factory: compiles a calibrated robot to embedded C for Arm SoCs\n (Cortex-A / Cortex-M) with a signed attestation manifest. Consumes Jaxterity.\n\nThe boundary rule: anything useful to controls engineers *outside* robotics\n(HVAC, battery, aerospace, energy) belongs in Jaxonomy; anything specific to\njoints, actuators, contacts, and kinematic chains belongs in Jaxterity;\nembedded codegen, targets, and attestation belong in Jaxility.\n\nWhat Jaxonomy does **not** yet do (or does only partially) is tracked in\n[`KNOWN_GAPS.md`](https://github.com/machinavitalis/jaxonomy/blob/main/KNOWN_GAPS.md) — the public inverse of the internal evidence\nledger in `CLAIMS.md`.\n\n## License\n\nReleased under the [MIT License](https://github.com/machinavitalis/jaxonomy/blob/main/LICENSE.md) from version 2.2.0 onward.\n\nDerived from the MIT-licensed open-source package **pycollimator** by **Collimator, Inc.**\n\n\n",
"bytes": 27982,
"sha": "6353708b2b6d51cc75850fa5e649eb78e4deb2fd047a38b822788ed295576558",
"repo_slug": "machinavitalis/jaxonomy",
"fonte": "repo",
"truncated": false,
"api": "https://agentalog.com/api/listings/mcp_io_github_machinavitalis_jaxonomy_39550151/readme"
}